Introduction
Collision detection is a common feature of many animation tools, so a question that sometimes is asked when students first start using Alice is “where is built-in support for collision detection?”. The short answer is that there isn’t any. Remember that Alice is a programming environment in which students can develop animations, as opposed to a purpose built animation tool. However, because it is a programming environment, Alice gives programmers the ability to readily develop their own support for collision detection. This tutorial provides a description of how such collision detection support can be implemented.
The Alice World
The world for this tutorial consists of a Humvee van and a number of obstacles. Event handling methods and event handlers have already been implemented that allow the user to move the car around the world. For example the code for driving the Humvee forward is as follows. A “Do together” block is used to drive the move the car forward and at the same time rotate the wheel.
humvee.driveforward()
  No variables
  Do together
    humvee move forward 5 meters
    humvee.frontRightWheel turn forward 1 revolutions
    humvee.backLeftWheel turn forward 1 revolutions
    humvee.backRightWheel turn forward 1 revolutions
    humvee.frontLeftWheel turn forward 1 revolutions
Setting up collision detection
To set up collision detection and collision avoidance we begin by adding a method, called collision, to the world object that detects and reacts to collisions. We begin by setting this up for a single obstacle, in this case a building and then extend the code so that we can handle multiple obstacles. To detect a collision we use the “is within threshold of” function from the humvee object. This is used as the conditional of an if-then-else statement. If the condition is true, then the humvee reacts to the collision by moving backwards a short distance.
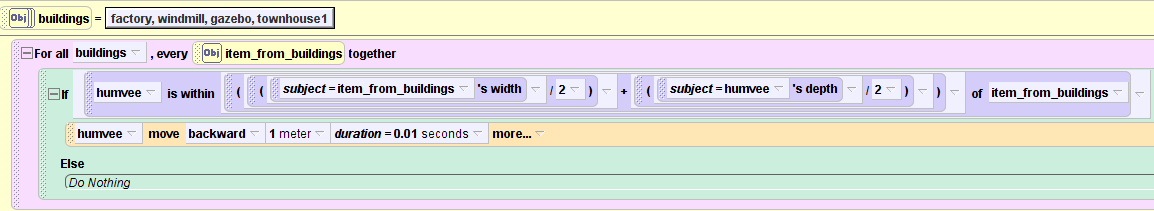
When using the “is within threshold of” function, we need to bear in mind that the function is measuring the distance between the centre of the Humvee and the centre of the obstacle. A collision with the side of the obstacle will therefore occur when the distance between the centres is half of the obstacle width + half of the Humvee depth. This distance will when the Humvee is approaching from a different direction, e.g. from the front of the building (in which case we might use the half of the obstacle depth). For this tutorial we just use the above calculation, but we could include a more sophisticated check by determining which direction the Humvee is approaching the obstacle from using the “is in front of” and similar functions.
After developing the collision method, we create a “while world is running” event handler. This event handler will call the collision method, such that whenever a collision is detected the Humvee will react and move backwards.
Dealing with multiple obstacles
So far we can only handle a single obstacle. We could of course develop similar methods to handle the other obstacles, but the DRY (don’t repeat yourself) principle suggests we should find a better way of doing this. Rather than repeating the code for the other obstacles, what we will do is generalise the existing code to handle many obstacles. To do this we use an list variable to represent the collection of all obstacles and then use the “for all do together” construct to implement collision detection and avoidance within a single method.
Video Tutorial
The following video tutorial provides a step-by-step description of the development of the collision detection capabilities.
http://www.youtube.com/watch?v=2gstaiVGqkk